Robot
Seek
A crawler robot with a work manipulator, built to operate in harsh environments.
Overview
Key Features
In development: Nov 2024 – present
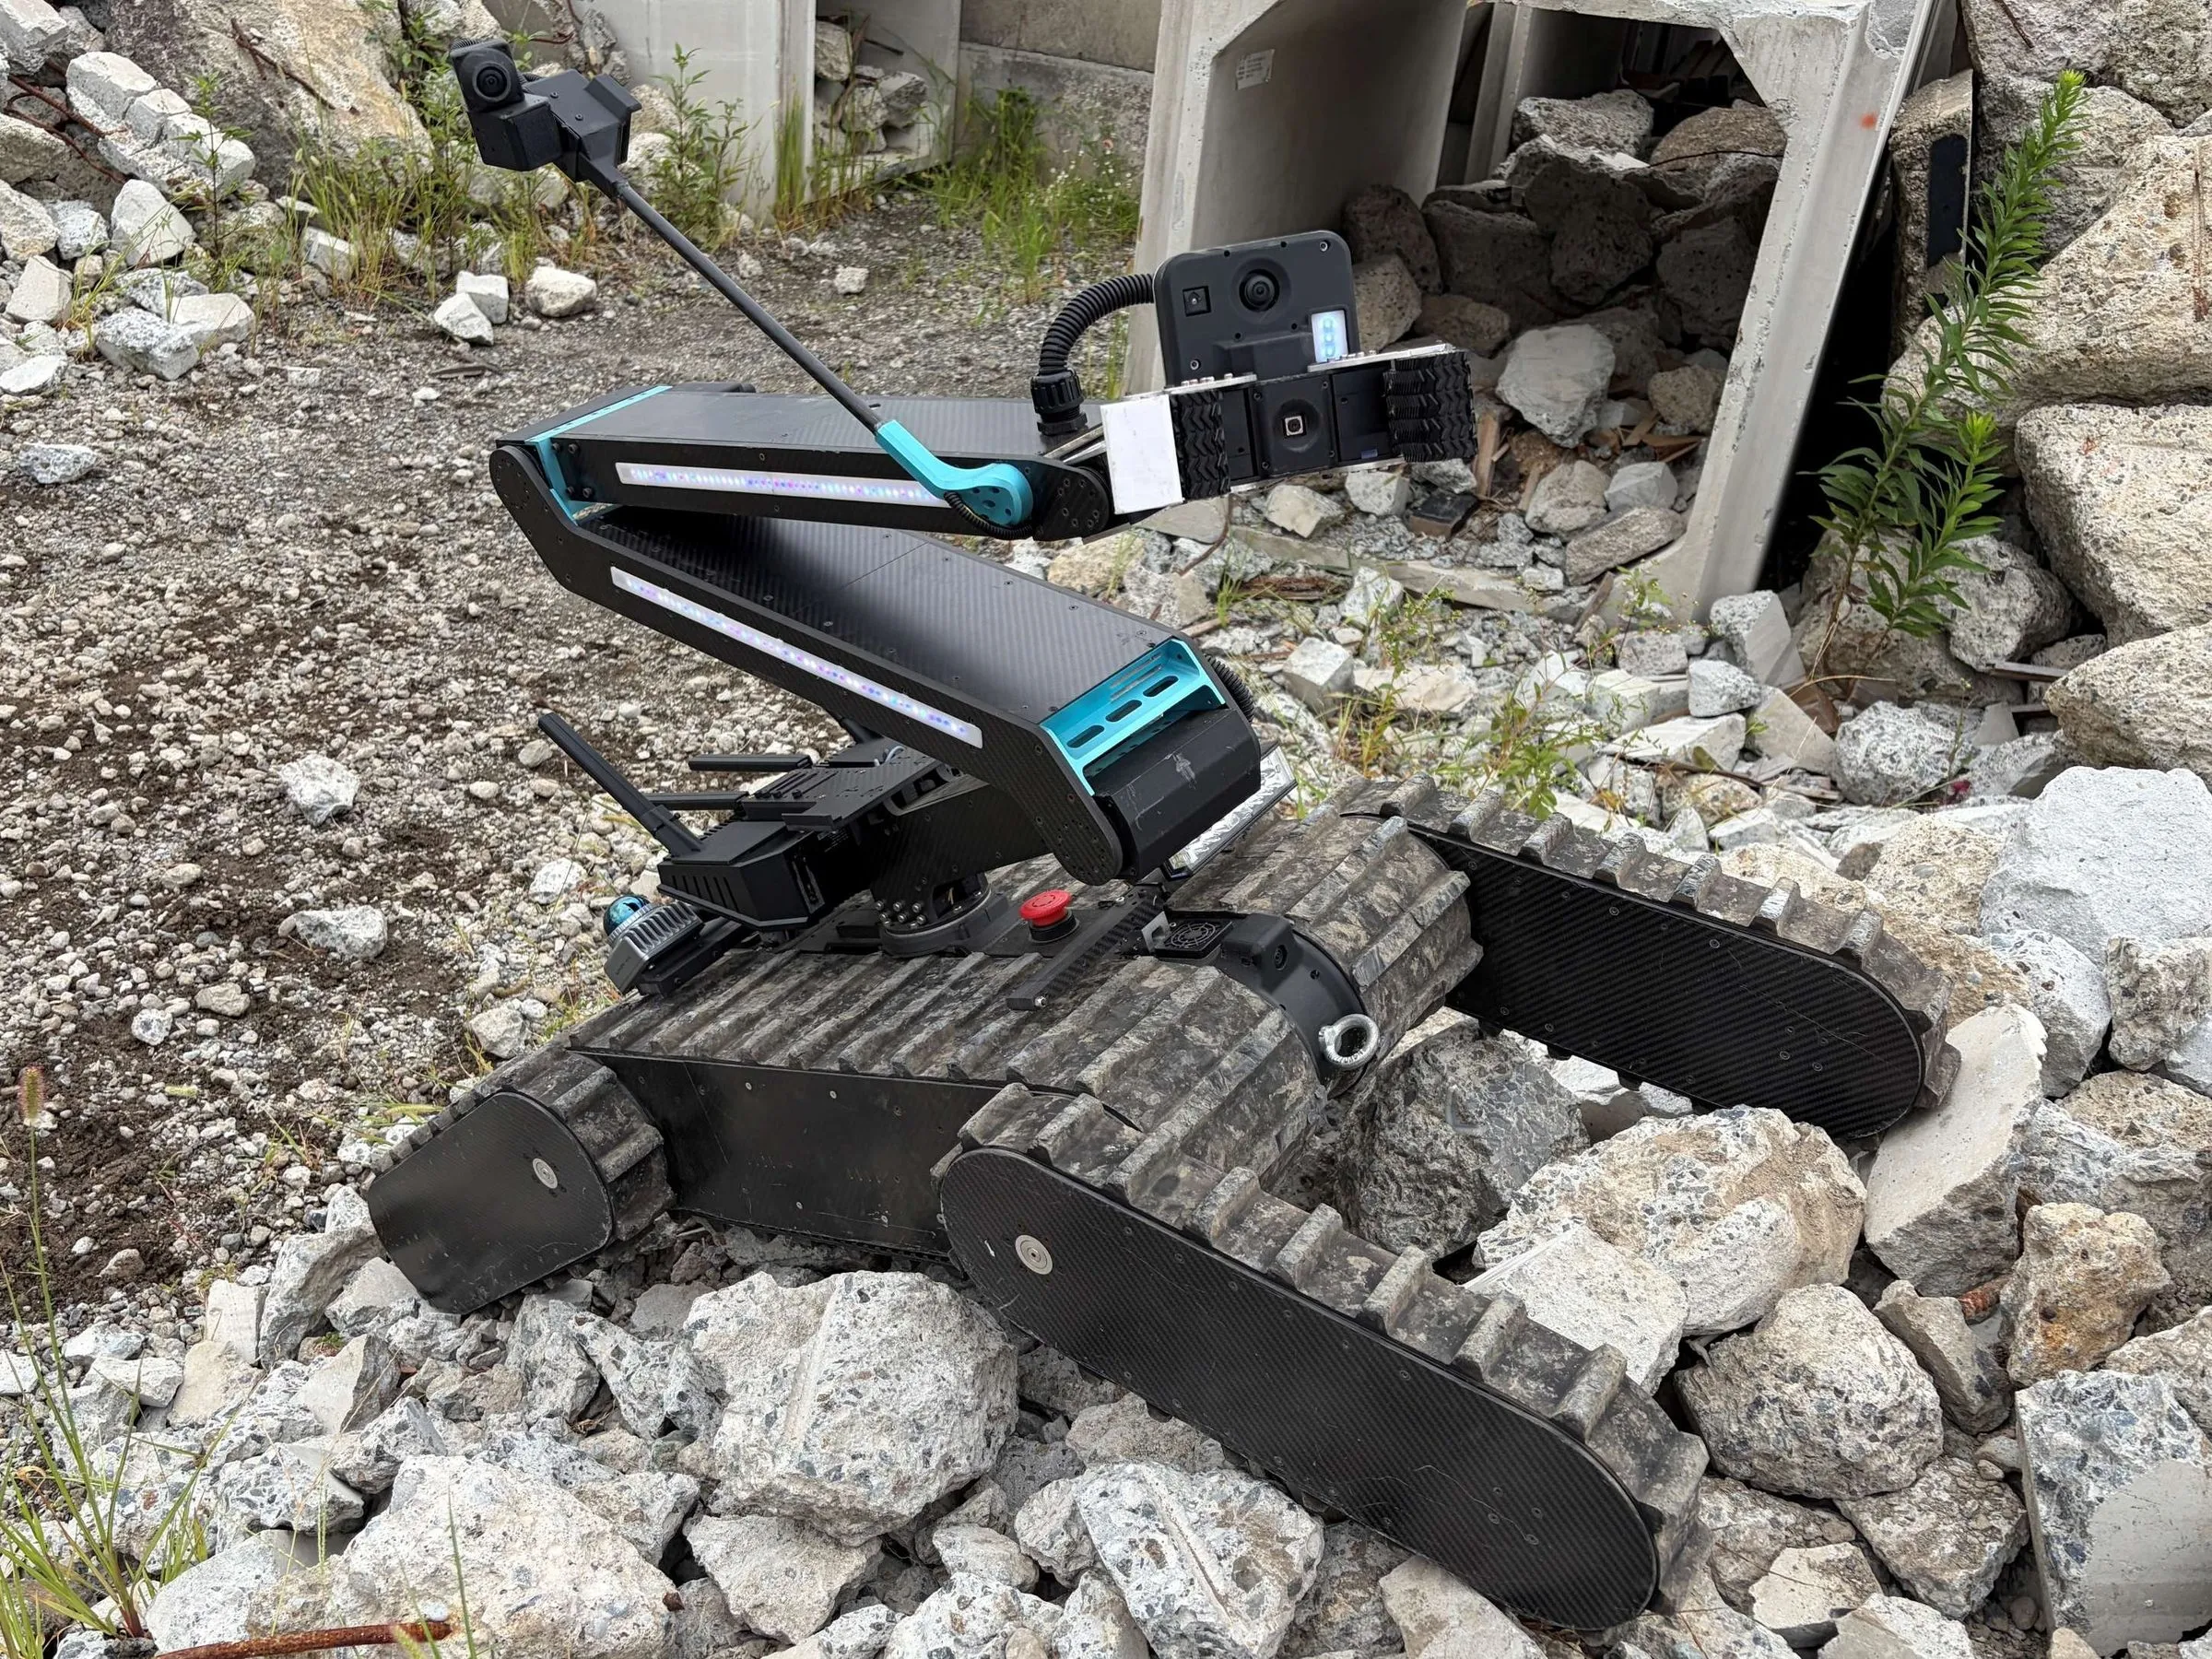
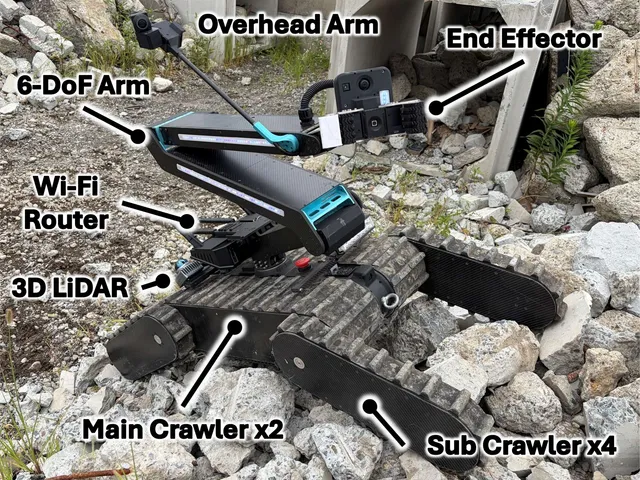
A main crawler covering the body and four sub-crawlers give Seek excellent mobility. It carries a 1.5 m 6-DoF arm, a 3-DoF overhead arm with a camera, five monocular cameras, a thermal camera and a 3D LiDAR for detailed exploration.
Mobility
Main crawler covering the body plus four sub-crawlers
Arms
A 1.5 m 6-DoF arm with an end effector (lifts up to 3 kg), plus a 3-DoF overhead arm with a camera for viewing the robot from above
Sensors
Five monocular cameras, a thermal camera and a 3D LiDAR
Basic Water Resistance
The wiring is kept enclosed, giving basic protection against water
Operation
Remote Operation
Game Controller
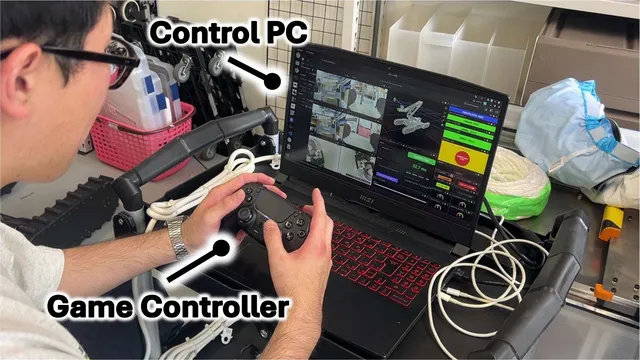
A single off-the-shelf game controller drives the robot and moves the arm
Control PC
Camera feeds, the 3D pose of the robot and its arm, the control mode and the link status on one screen
Wireless Link
Operated over the Wi-Fi router on the robot from places where the robot is out of sight (beyond-line-of-sight operation)
Use Cases
Intended Applications
Its mobility and versatility should make it useful in a wide range of fields.
- Disaster-site surveys
- Infrastructure inspection
- Work in hazardous areas
Gallery
Seek at Work
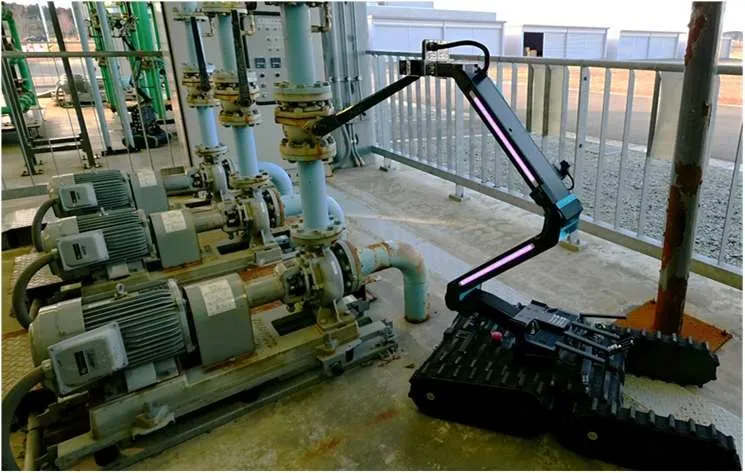
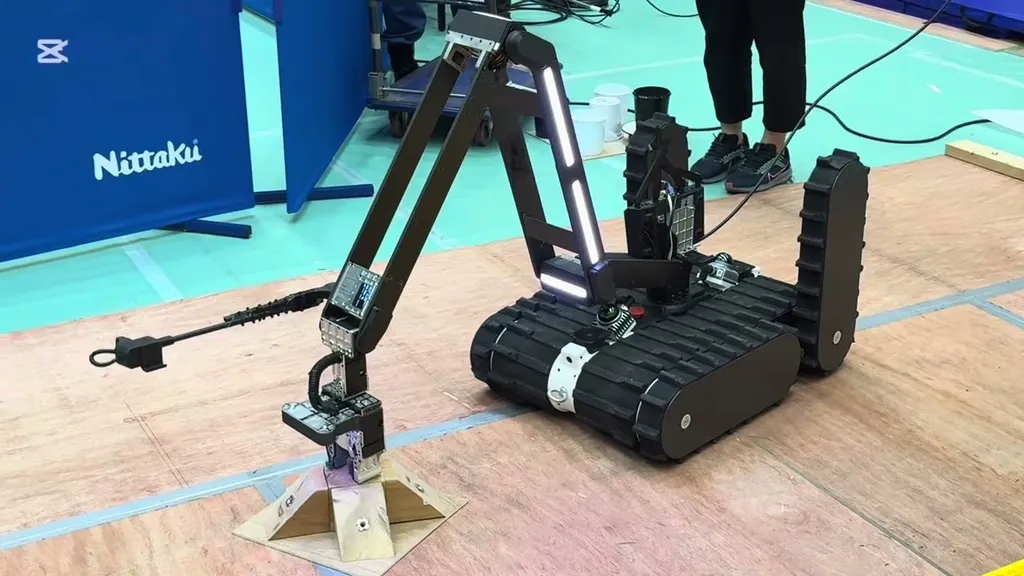
Operating a lever in a plant 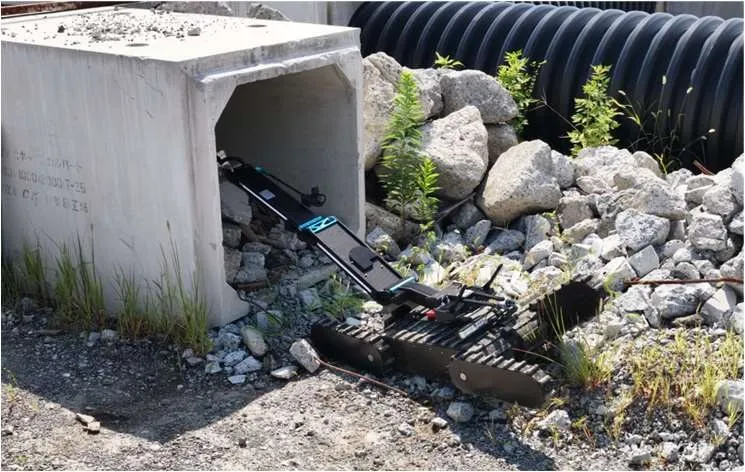
Searching for survivors in simulated rubble
Track Record
Track Record
Competition
World Robot Summit 2025 Harsh Environment F-REI Challenge — Plant Disaster ChallengeWinner
Minister of Economy, Trade and Industry Award
Exhibitions
Live demonstrations at iREX2025 (International Robot Exhibition 2025) and RISCON TOKYO 2026
Drills
Training with the Japan Ground Self-Defense Force and firefighters at Big Rescue Kanagawa, a joint disaster drill in Atsugi
Movie
Seek in Action