Technology
Technology
We develop all the technologies our robots need. Both hardware and software are built in-house, and we keep building up our know-how as we go.
Hardware
Design with 3D CAD
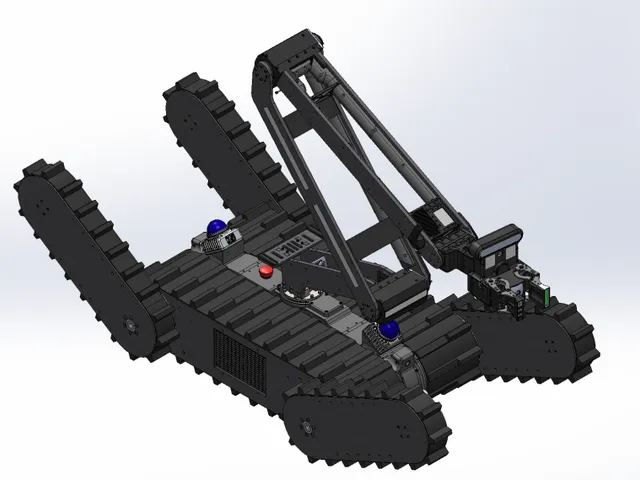
Hardware
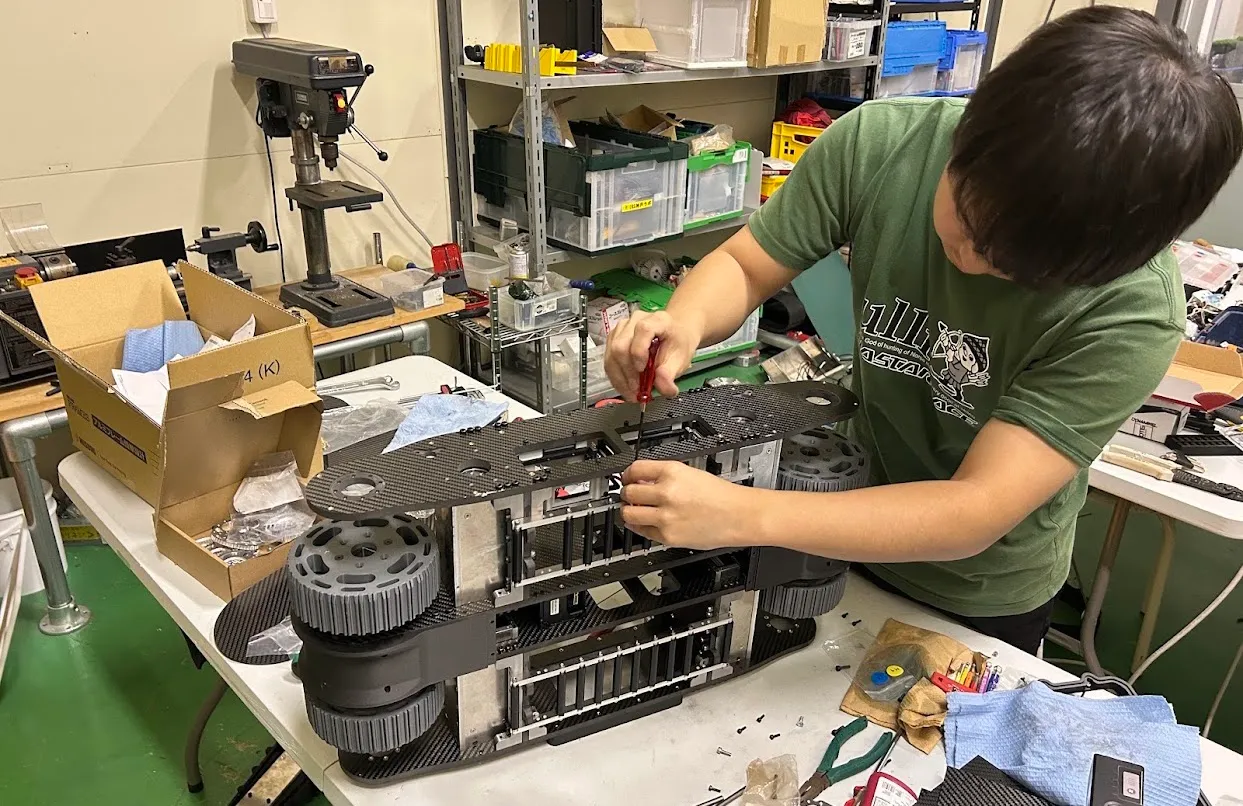
Fabrication and Assembly
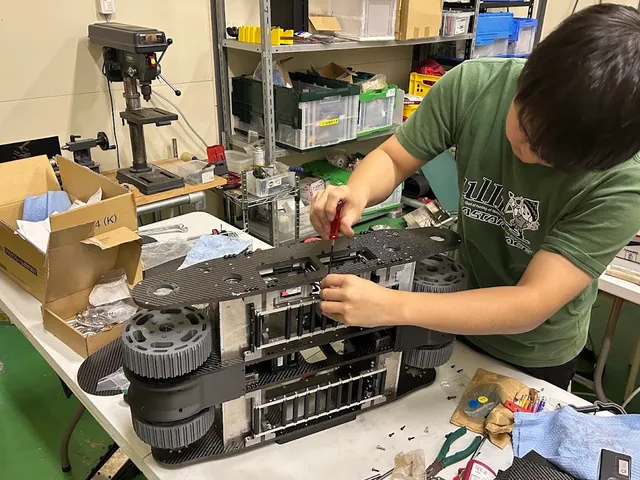
Software
Software
- ROS 2
Control with ROS 2
Our robots run on the ROS 2 robotics middleware. Everything from multi-camera video and audio links for remote operation beyond line of sight to motor control and inverse kinematics for the arm is developed quickly with ROS 2.
- YOLO
- Vision
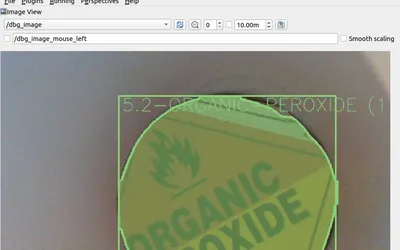
Object Recognition with YOLO
The onboard 2D camera can recognise any object with YOLO. In the RoboCup Rescue Robot League, robots must correctly identify hazmat labels and report the results automatically.
- SLAM
- 3D LiDAR
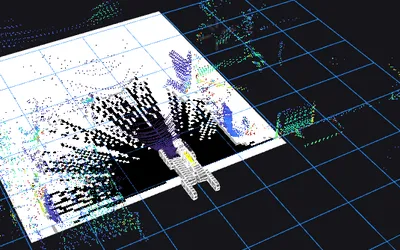
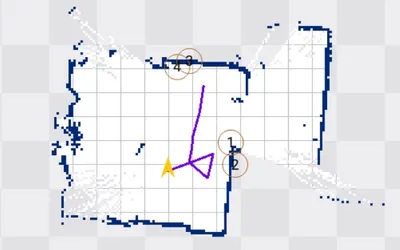
SLAM with LiDAR
With the onboard 3D LiDAR the robot performs SLAM and can build both 2D and 3D maps, including marking detected objects on the map.
Knowledge Sharing
Sharing Our Know-how
We actively share what we learn about software: our code is on GitHub and our ROS 2 articles (in Japanese) are on Zenn. We hope to contribute not only to our own team but to the whole rescue robot competition community.